To compare RC servo specifications, match the exact model and motion type, separate the supply voltage from the control signal, and compare torque and speed only at their stated conditions. Confirm dimensions, output interface, supplied horn and application support. A servo being sold for robotics or radio-controlled models does not establish its suitability for a particular drone.
Compare RC servo specifications in a fixed order: exact model, motion type, supply, control signal, torque and speed conditions, mounting, output interface and supplied hardware. If the motion type or control interface is unresolved, stop before comparing headline torque.
This guide helps buyers screen an existing standard-servo replacement. It is not a wiring guide, flight-control setup or method for sizing an actuator from aircraft loads.
Record the complete manufacturer model and every suffix. Then classify the documented function: limited-angle position control, continuous rotation speed control or another named actuator type.
Pololu’s FS5106B page provides a useful warning. It describes the FS5106B as a limited-range position-control servo and the FS5106R as a continuous-rotation speed-control servo, while stating that the two have identical dimensions and the same motor and gear reduction. A matching case therefore does not prove matching motion.
Use hold when the exact suffix or motion type is unknown. Do not ask torque to resolve an identity problem.
The FS5106B specification page lists 4.8 kg·cm stall torque and 0.13 s/60° at 4.8 V, and 6 kg·cm and 0.11 s/60° at 6 V. These values belong to the named model and conditions; they are not a drone recommendation.
| Field | Value to preserve | Do not convert it into |
|---|---|---|
| Stall torque | Rating type + voltage | A continuous-load recommendation |
| Speed | Time/angle + voltage + stated condition | Loaded motion in the buyer’s installation |
| Dimensions | Full drawing/reference | Proof of motion or mounting compatibility |
Do not calculate a permitted continuous load from stall torque. Obtain the manufacturer limits and responsible application review.
Use three fields: power supply requirements, control-signal requirements and documented connector/pin assignment. The FS5106B page says the named servo can work with 3.3 V and 5 V control signals; that does not say a 3.3 V power supply is acceptable.
A familiar three-wire lead is not permission to guess the pinout. If the exact model’s connection document is missing, record hold for documentation. This article does not provide an improvised connection test.
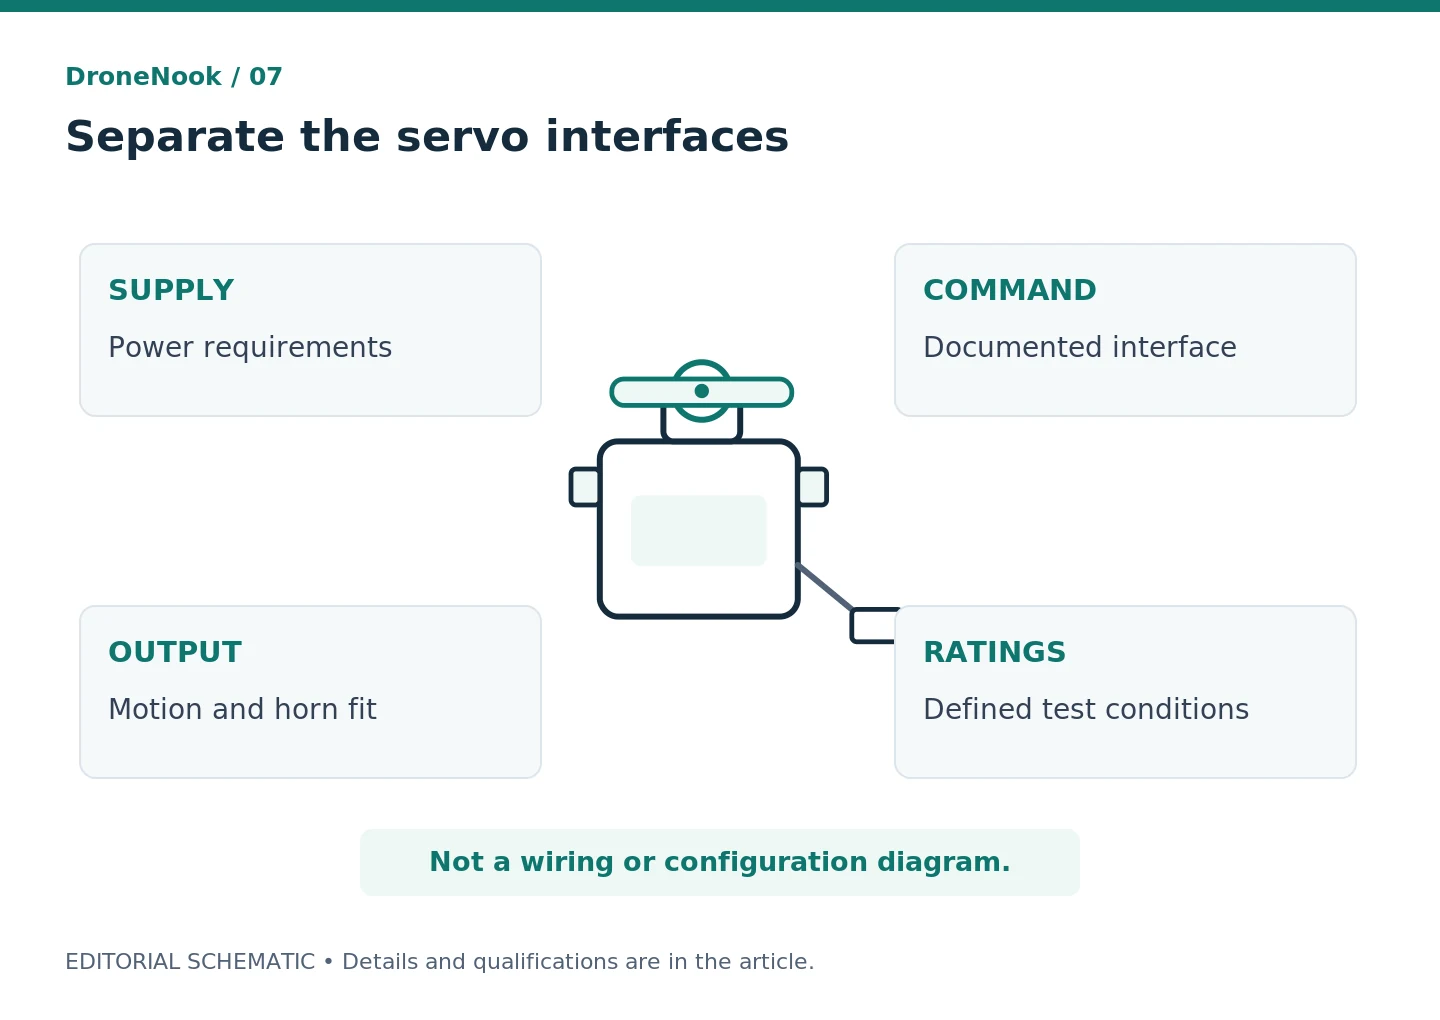
Power, command and mechanical interfaces are separate checks. This is not a wiring diagram.
“Digital” can describe internal control behaviour; it does not by itself identify the external interface. The original Pololu servo-interface article treats pulse voltage, pulse width and pulse period as distinct parameters. Use the exact model documentation to identify the supported command signal.
Record one of: documented pulse interface, documented serial bus, another named interface or unknown. Unknown is not equivalent to PWM, and a change of control architecture requires a technical owner.
Compare the mounting-hole pattern, output-shaft position, body envelope, lead exit and clearance against the accepted reference. Case width alone is insufficient.
For the horn, record the manufacturer’s output/spline reference, fastening method and supported horn part. Then state whether the quote includes the body, horn set and hardware. “Standard size” and “metal gear” do not answer those questions.
Use the package-contents guide to compare a body-only offer with a complete replacement scope.
| Field | Existing accepted record | Quoted item | Status |
|---|---|---|---|
| Exact model/suffix | Record | Record independently | Hold if different/unknown |
| Motion type | Position/continuous/other | Manufacturer-documented | Must agree with requirement |
| Supply | Range and conditions | Range and conditions | Technical review if different |
| Control | Exact interface | Exact interface | Hold if inferred |
| Torque/speed | Definition, voltage, condition | Same comparison basis | Open if conditions differ |
| Mount/output | Accepted drawing and horn | Drawing and horn reference | Hold if any interface open |
| Contents | Required scope | Included/excluded | Commercial scope match |
A higher stall-torque number cannot close an unresolved motion, control or mounting question.
If the seller cannot document a required field, leave it open and name the person who must resolve it. Avoid turning “Will it work on my drone?” into an unsupported sales yes/no answer.
A sample can confirm identity, supplied contents and specified dimensional observations. Functional or load evaluation needs a qualified plan and manufacturer guidance. Do not energize, stall or back-drive an unknown servo as a receiving shortcut.
Record the sample’s exact reference and change status. Use the sample-request guide to prevent one sample result from becoming blanket approval of later revisions.
No. Use the exact model’s interface documentation; the label alone does not establish pulse or serial-bus control.
No. It is a named rating condition, not a continuous-use recommendation. Keep voltage and rating definition attached.
No general conclusion follows. FS5106B and FS5106R are a documented example of identical dimensions with different motion functions.
No. A catalog category is not approval for a specific aircraft or function. Use the responsible manufacturer’s or technical party’s acceptance process.
Send the exact model/suffix, motion type, required horn, quantity and comparison worksheet. If the reference is uncertain, start with the part-number guide. Mark alternatives separately from a same-reference replacement.
Sources checked on 22 October 2026: Pololu’s FS5106B product/specification pages and the original Pololu servo-interface article. The model is a specification-reading example only; DroneNook does not represent it as approved for any aircraft.